April 1, 2022
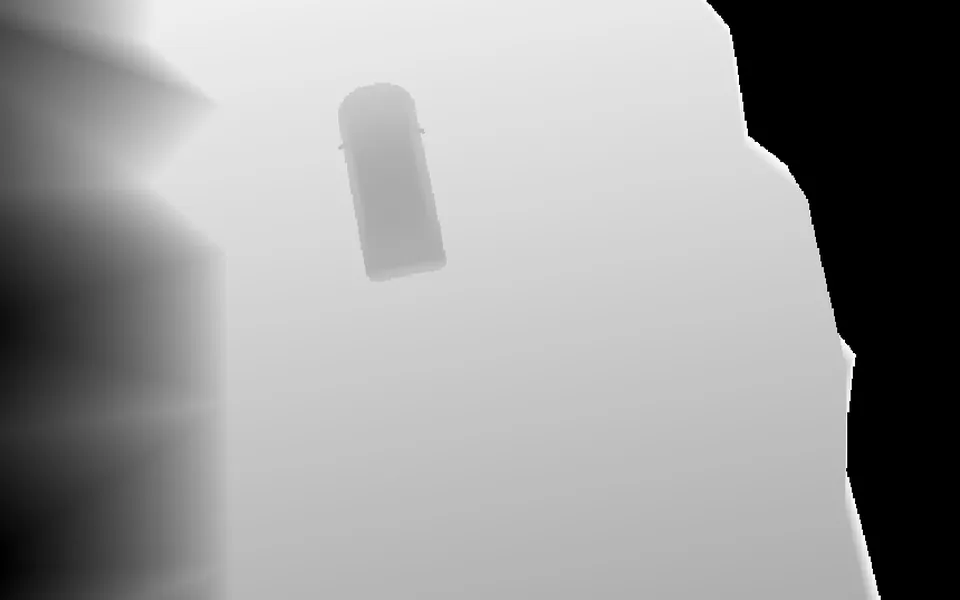
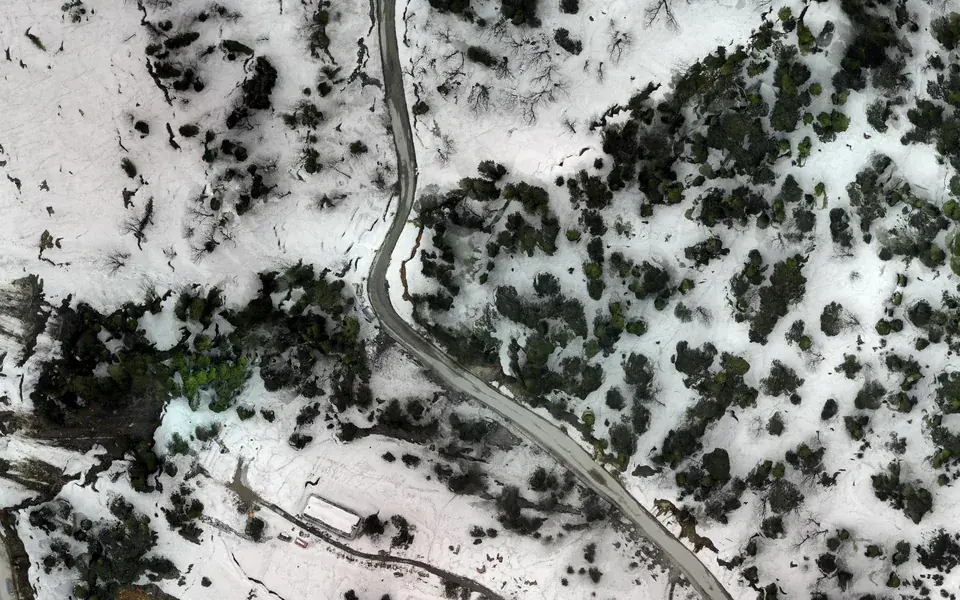
Designed a UAV travel algorithm employing K-means segmentation and Depth-Vision for trajectory construction, with stable path-following using PID control and Differential Kinetics. Developed a computation-efficient pipeline for ROS code, optimizing image processing and robot control mechanisms.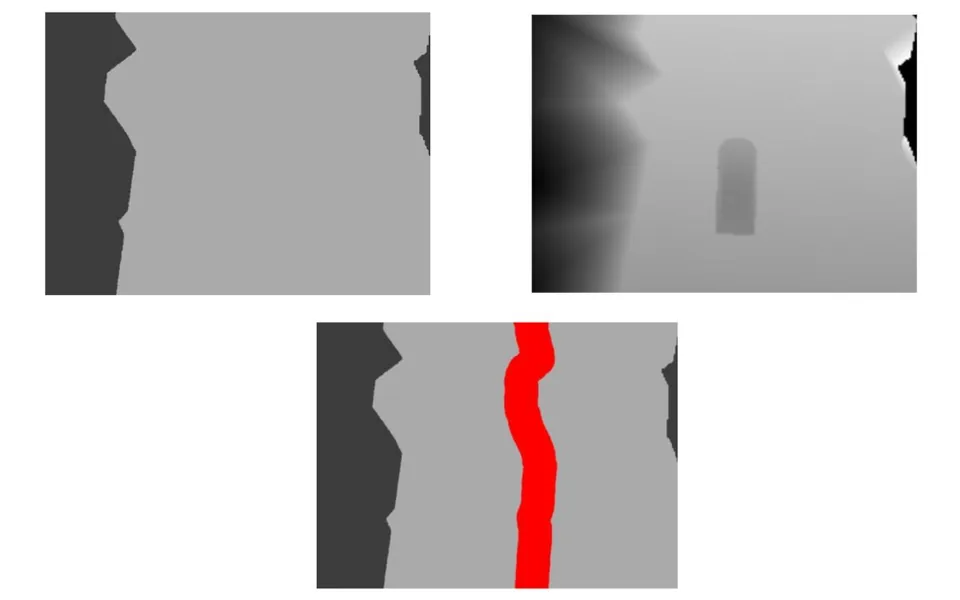
 View project