August 1, 2022
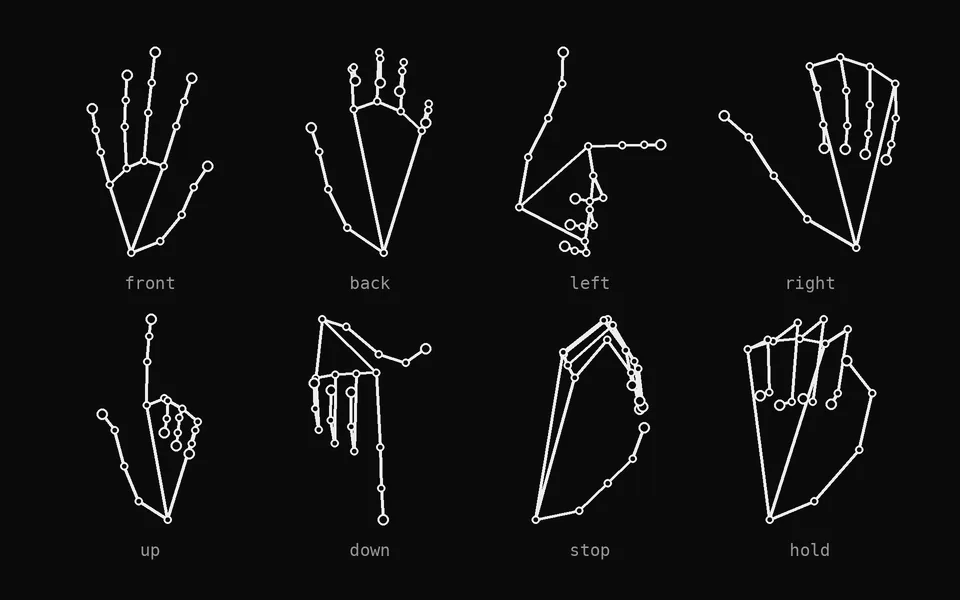
Designed and implemented a vision-based semi-autonomous mining robot using ROS incorporating instance segmentation, hand detection (YOLO & Keypoint Mapping), and real-time gesture action classification (LSTM) with path planning to address challenges in the mining industry.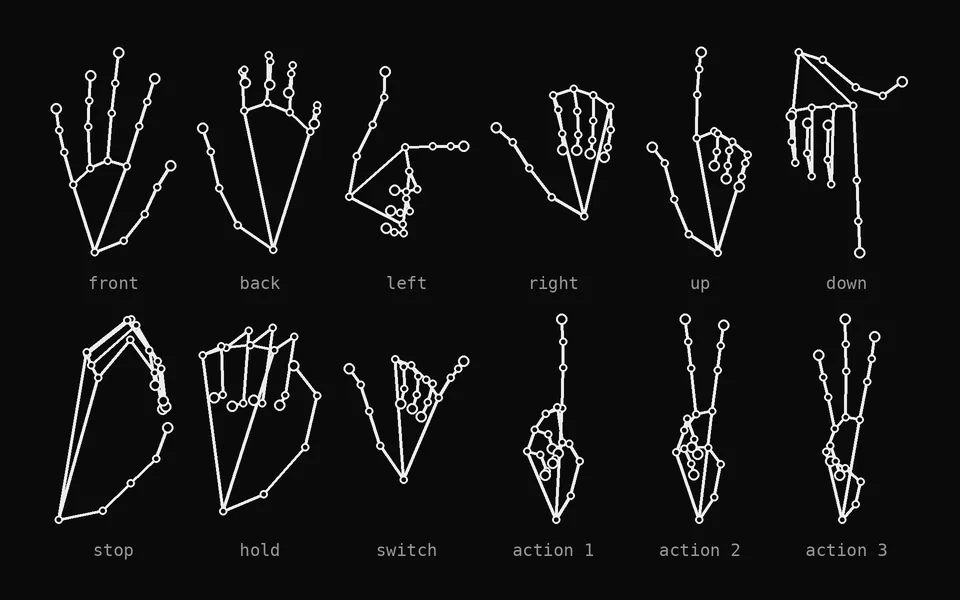 View project